
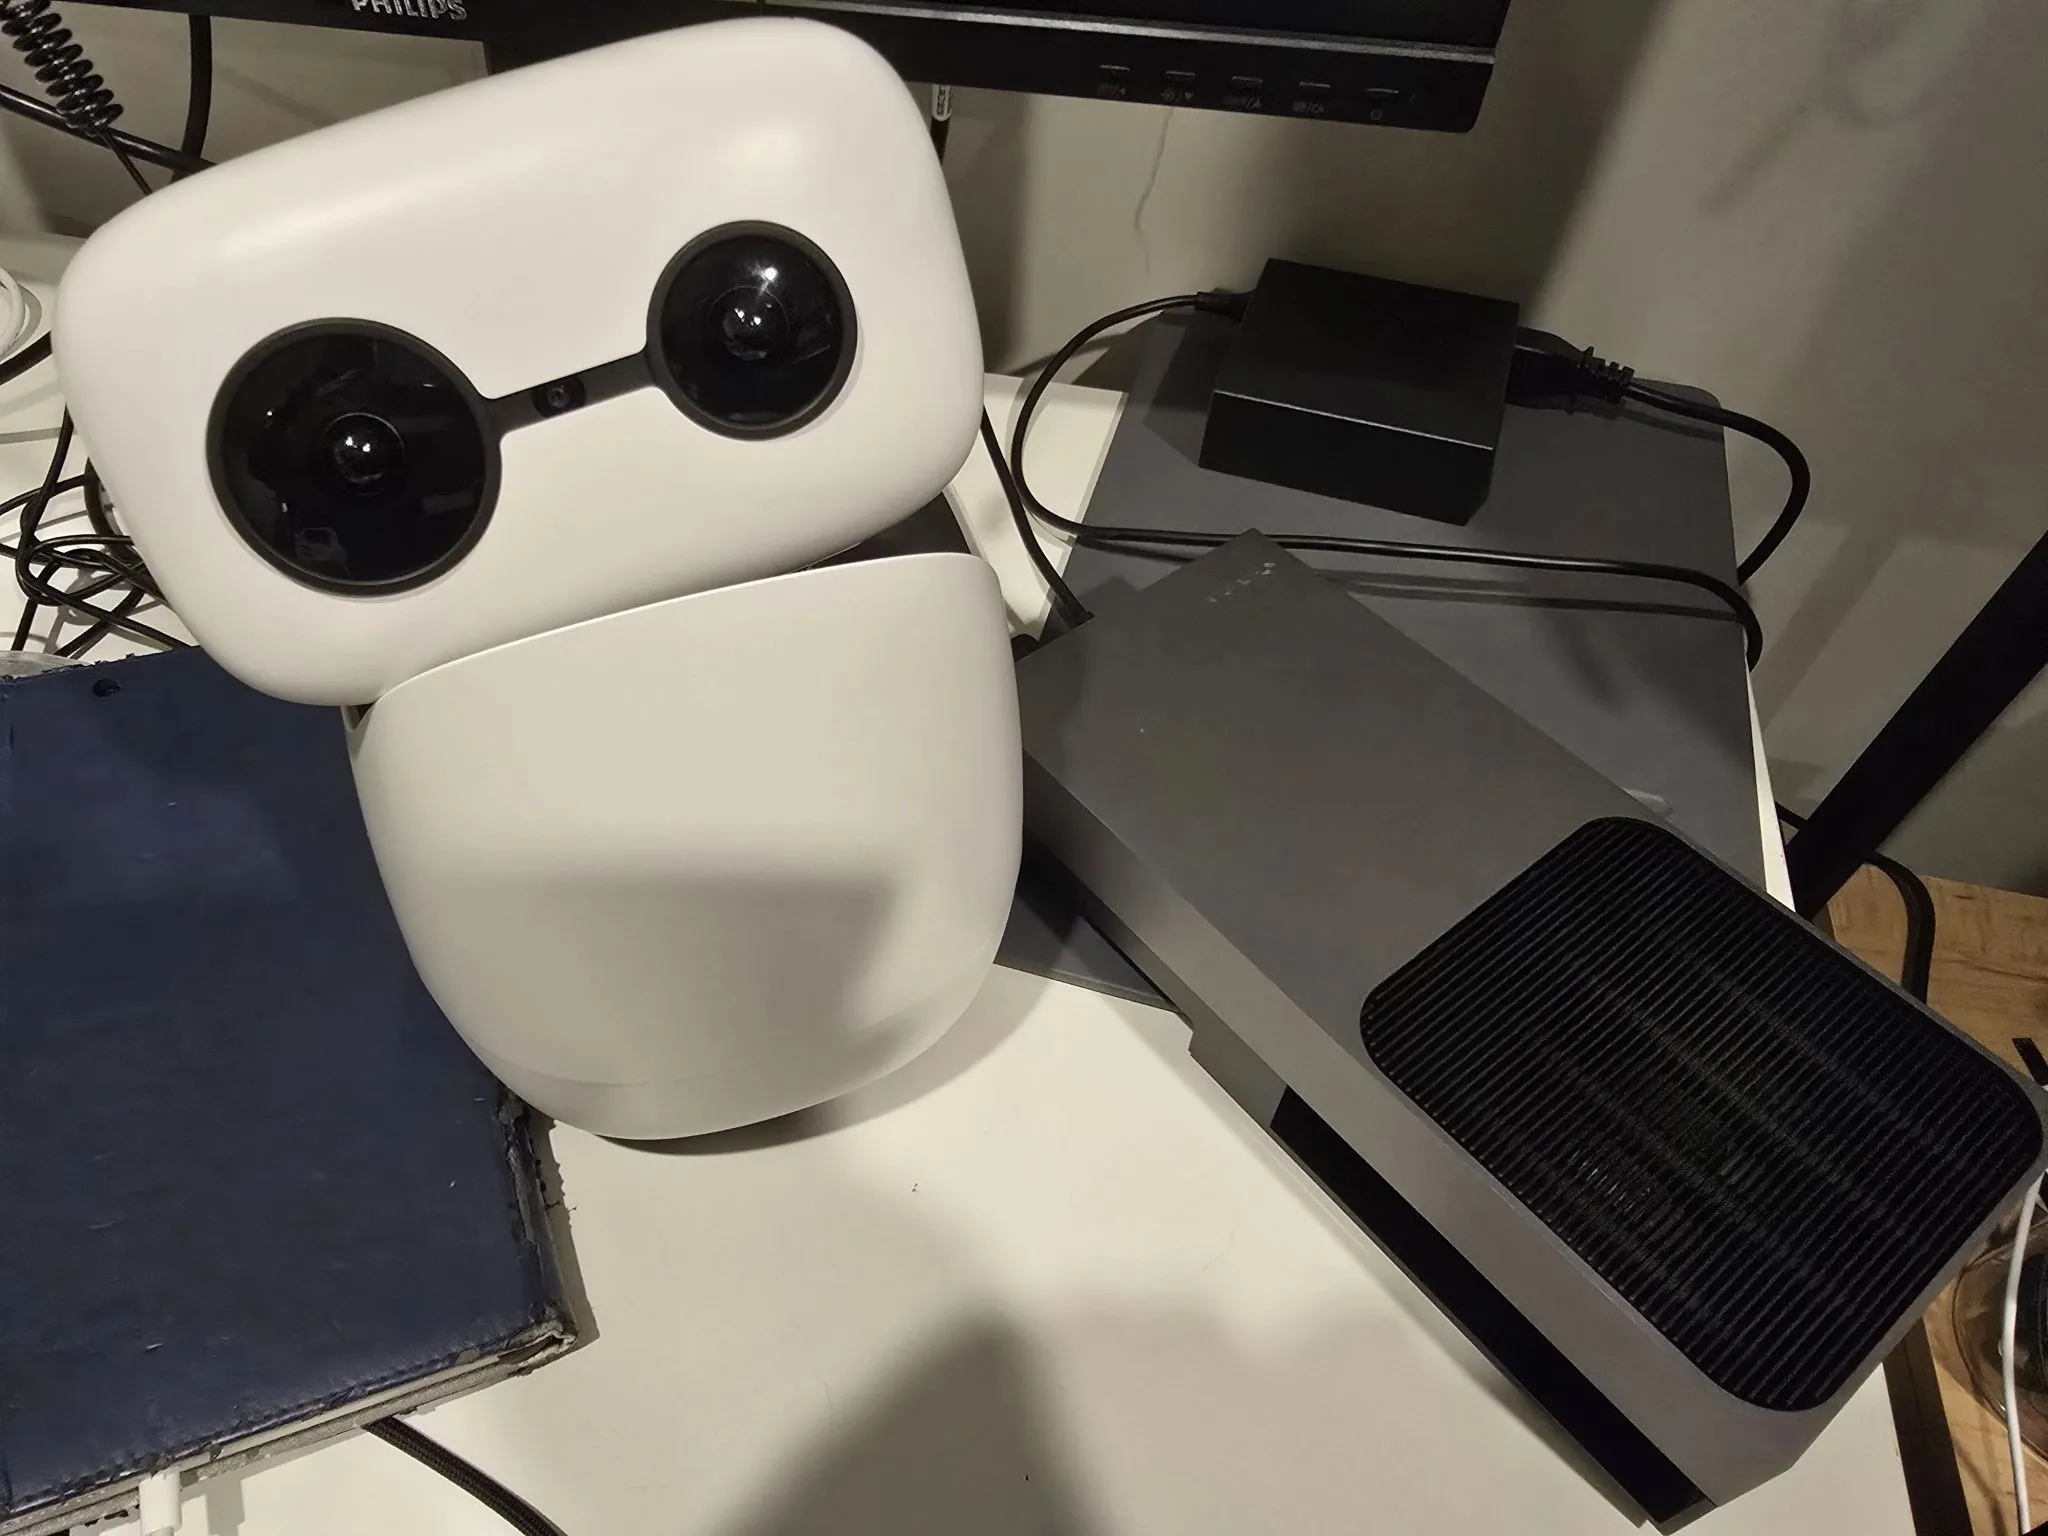
Reachy Mini x Strands Agent on Jetson Thor - Part 9: Idle Presence — Noticing Who's Around (Humans vs Cats)
Part 9 of the series: while resting, the robot periodically asks Cosmos who it sees — fully local, $0 — and routes the observation through species-specific Strands Agent tools so humans and cats can trigger different behaviours, both, either, or neither firing per glance.
Series: Reachy Mini x Strands Agent on Jetson Thor (14 articles)
- …
- 9Reachy Mini x Strands Agent on Jetson Thor - Part 9: Idle Presence — Noticing Who's Around (Humans vs Cats) This article


What would I like to build?

This is Part 9 of the series. So far the robot only acts when triggered — a wake word or an MQTT message. Now I want it to show a little life between interactions: while resting, it should quietly notice who's in the room and have a place to hang future reactions — greet a person, perk up at a cat.
Every
IDLE_INTERVAL seconds the robot grabs a frame, asks NVIDIA Cosmos Reason 2 who it sees, and routes the observation through a tiny Strands Agent. The whole thing is fully local — local Cosmos vision, local Nemotron routing — so each glance costs $0, in keeping with the idle-is-free principle that runs through the build.The design choice worth highlighting is the species split. Instead of one generic
report_presence, the observation routes to two tools — report_human_presence and report_cat_presence — so people and cats can drive different behaviours. A single glance can fire both (a person and a cat in frame), either alone, or neither.Goals
- Have the robot periodically notice who's around while idle, fully local and $0
- Use Cosmos Reason 2 to count people and cats and note what each is doing
- Route the observation through a minimal, disposable Strands Agent to species-specific tools
- Support both / either / neither firing per glance — humans and cats are independent
- Never compete with a real task — skip ticks while the robot is busy
- On a real detection, record a clip (S3) and publish a
presencestate (IoT Core) for downstream systems
The Overall System
A daemon thread ticks on a fixed cadence. Each tick samples the shared camera frame, asks Cosmos a counts-per-species question, and hands the answer to a throwaway agent that routes to the human and/or cat tool — which, on a real detection, record a clip and publish a presence event.

System Components:
_idle_watcher— the daemon-thread loop on anIDLE_INTERVALcadence- Shared camera buffer —
_latest_jpeg_b64(), the same frame the face tracker maintains - Cosmos Reason 2 — answers the counts-per-species
IDLE_QUESTION, locally _run_presence_agent— a minimal Strands Agent built per observation and discardedreport_human_presence/report_cat_presence— the two species tools, each logging and (on a detection) recording + publishing
Sequence Diagram
Follow one tick where a person and a cat are in frame — observation, species routing, both tools firing, and the clip/state upload.

Architecture
| Tool | Args | presence_kind | Log colour |
|---|---|---|---|
report_human_presence | people, description | human | magenta |
report_cat_presence | cats, description | cat | cyan |
Both are
@tool-decorated. Each logs a colour-coded line, and only when its count is >= 1 does it record a short clip (record_clip_and_upload() → S3, presigned URL) and publish a presence state message over IoT Core. The presence agent itself is built and discarded per observation, so nothing persists between ticks.How it works
The idle watcher
_idle_watcher() runs on a daemon thread started at boot. While the robot is resting it loops on a fixed cadence: every IDLE_INTERVAL seconds (default 10) it grabs the latest frame from the shared camera buffer with _latest_jpeg_b64(), sends it plus IDLE_QUESTION to Cosmos Reason 2, prints the observation, and hands it to a Strands Agent. It is fully local, so each tick costs $0. The default IDLE_QUESTION asks for counts and a short note per species:1
2
How many people and how many cats can you see? Give the count of each (0 if none)
and a short note on what each is doing.Skipping ticks while a task runs
The watcher checks the shared
_busy event at the top of every tick. If a real task is running it logs idle watcher: skip tick (busy with a task) and waits for the next interval, so the presence check never competes with a live look or drives the GPU mid-task:1
2
3
4
5
6
7
8
while True:
time.sleep(IDLE_INTERVAL)
if _busy.is_set():
vlog("idle watcher: skip tick (busy with a task)")
continue
ans = _look_via_server(IDLE_QUESTION, image=True, image_b64=_latest_jpeg_b64())
...
_run_presence_agent(ans)Routing one observation to two tools
_run_presence_agent(observation) builds a minimal Strands Agent for that single observation, registers both presence tools, and discards the agent afterward (del + gc.collect()). Its system prompt routes by species:- one or more people present → call
report_human_presence - one or more cats present → call
report_cat_presence - both present → call both tools
- neither present → do nothing, emit no prose
The species-specific tools
Each tool logs a line, and only on a real detection does it record and publish — so a fully local run (no S3/MQTT) just logs:
1
2
3
4
5
if people >= 1:  # only upload when something is actually detected
    video_url = record_clip_and_upload()
    publish_state("presence", presence_kind="human", presence_count=people,
                  presence_description=description,
                  **({"video_url": video_url} if video_url else {}))
report_cat_presence is identical with presence_kind="cat". Both the clip upload and the state publish are no-ops when S3/MQTT (or the camera owner) are unavailable.Configuration
| Env var | Default | Purpose |
|---|---|---|
IDLE_WATCH | 1 | Set to 0/false/no/off to disable the watcher |
IDLE_INTERVAL | 10 | Seconds between presence checks |
IDLE_QUESTION | counts-per-species prompt | Question sent to Cosmos Reason 2 |
Technical Challenges & Solutions
Challenge 1: Idle awareness that stays free
Problem: Continuously running vision to watch the room could peg the GPU and, on a cloud VLM, cost money around the clock.
Solution: The watcher ticks on a slow cadence (default every 10s), reuses the already-captured shared frame, and runs local Cosmos + Nemotron — so each glance is
$0 and the GPU is touched only briefly, on a timer.Challenge 2: Presence checks colliding with real tasks
Problem: If a user wakes the robot or an MQTT look arrives mid-tick, two vision workloads would contend for the GPU and camera.
Solution: Every tick first checks the shared
_busy event and skips if a task is running. The idle watcher always yields to a real interaction.Challenge 3: Humans and cats need different reactions
Problem: A single generic
report_presence can't let a person and a cat trigger distinct behaviours, and both can be present at once.Solution: Split into
report_human_presence and report_cat_presence, each independently fired by the routing agent. One glance can call both, either, or neither — giving a clean hook for per-species behaviour later, while today each records a clip and publishes a tagged presence event only when its count is real.Getting Started
Run it (and tune the cadence)
1
2
3
./reachy_assistant.sh                 # watcher on by default, every 10s
IDLE_INTERVAL=30 ./reachy_assistant.sh # slower cadence
IDLE_WATCH=0 ./reachy_assistant.sh     # disable the watcher entirely
While the robot rests, watch the log: it prints what Cosmos sees each tick and which presence tools fire.
What's Next
In Part 10 - Face Tracking with a Single Camera Owner , the head starts following your face in real time — and I dig into the single camera-owner thread that lets head tracking, the idle watcher, and Cosmos vision all share one camera without V4L2 contention.
Summary
This post covered idle presence awareness:
- Idle glances, fully local — every
IDLE_INTERVALseconds the robot asks Cosmos who it sees, at$0per tick - Yields to real work — ticks are skipped while
_busyis set, so presence never competes with a live task or the GPU - Species split —
report_human_presenceandreport_cat_presenceroute independently; both, either, or neither can fire per glance - Disposable router —
_run_presence_agentbuilds a minimal agent per observation anddels it, so nothing persists between ticks - Real detections only — clips (S3) and
presencestate (IoT Core) are recorded only when a count is>= 1, and no-op when the cloud paths are offMore in this series - Previous - Part 8: 80 Emotion Moves by Sentiment
- Next - Part 10: Real-Time Face Tracking
Series: Reachy Mini x Strands Agent on Jetson Thor (14 articles)
- …
- 9Reachy Mini x Strands Agent on Jetson Thor - Part 9: Idle Presence — Noticing Who's Around (Humans vs Cats) This article
Enjoyed reading this content? Let the author know!
Your likes, comments, shares, and saves help creators reach more builders.

Loading recommendations
Loading article